Developing Innovative Solutions for Rehabilitation Robotics
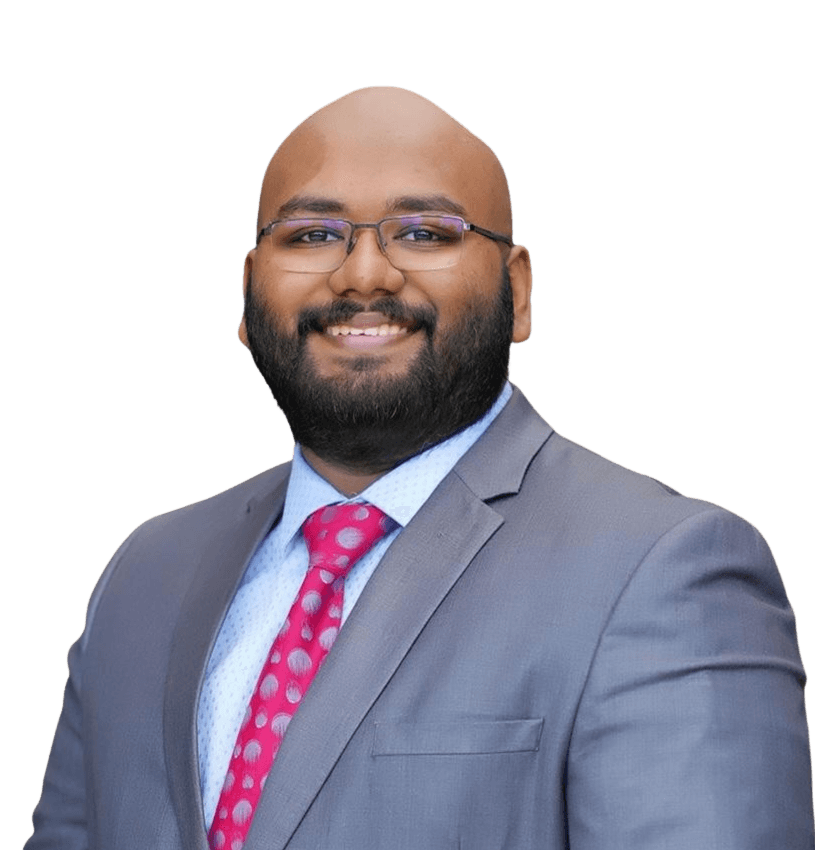
Hi, I am Jose Ben
PhD Student in Robotics at Northern Arizona University

The Arsenal Behind the Action...
 Arduino
 Matlab
 Pi
 ROS
 Python
 Docker
 OpenCV
 Git
 NodeJS
 NextJS
 Typescript
 JavascriptArduinoMatlabPiROSPythonDockerOpenCVGitNodeJSNextJSTypescriptJavascript
Things I've Engineered
From humanoid robots to IoT systems — where hardware meets software.
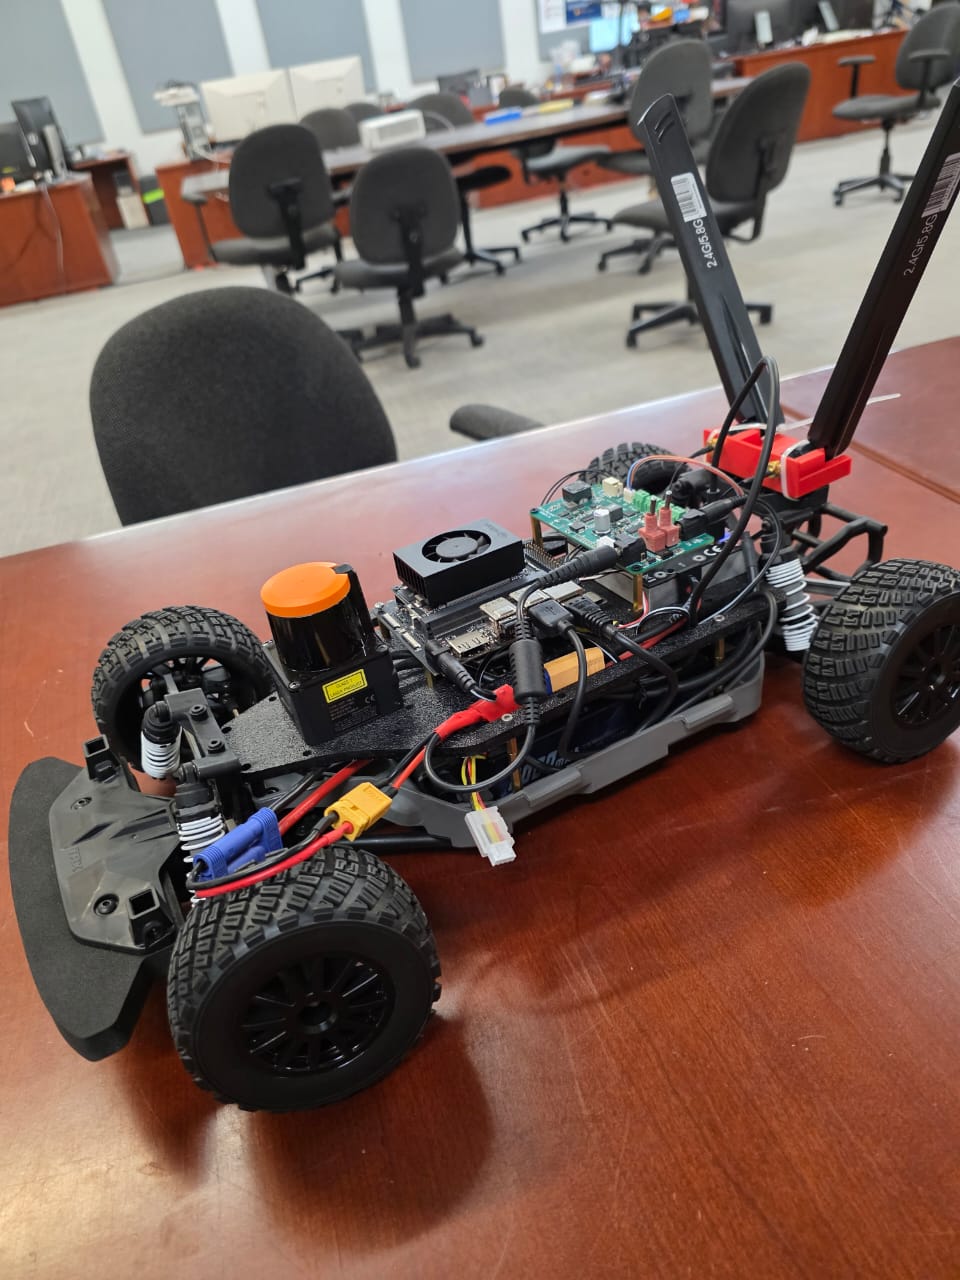
F1TENTH Autonomous Racing Car
Autonomous navigation stack for an F1TENTH 1/10-scale race car on an NVIDIA Jetson, using ROS 2 Humble, LiDAR-based obstacle detection, and a tuned Nav2 stack for high-speed reactive racing.
Bi-Manual Robotic Therapy
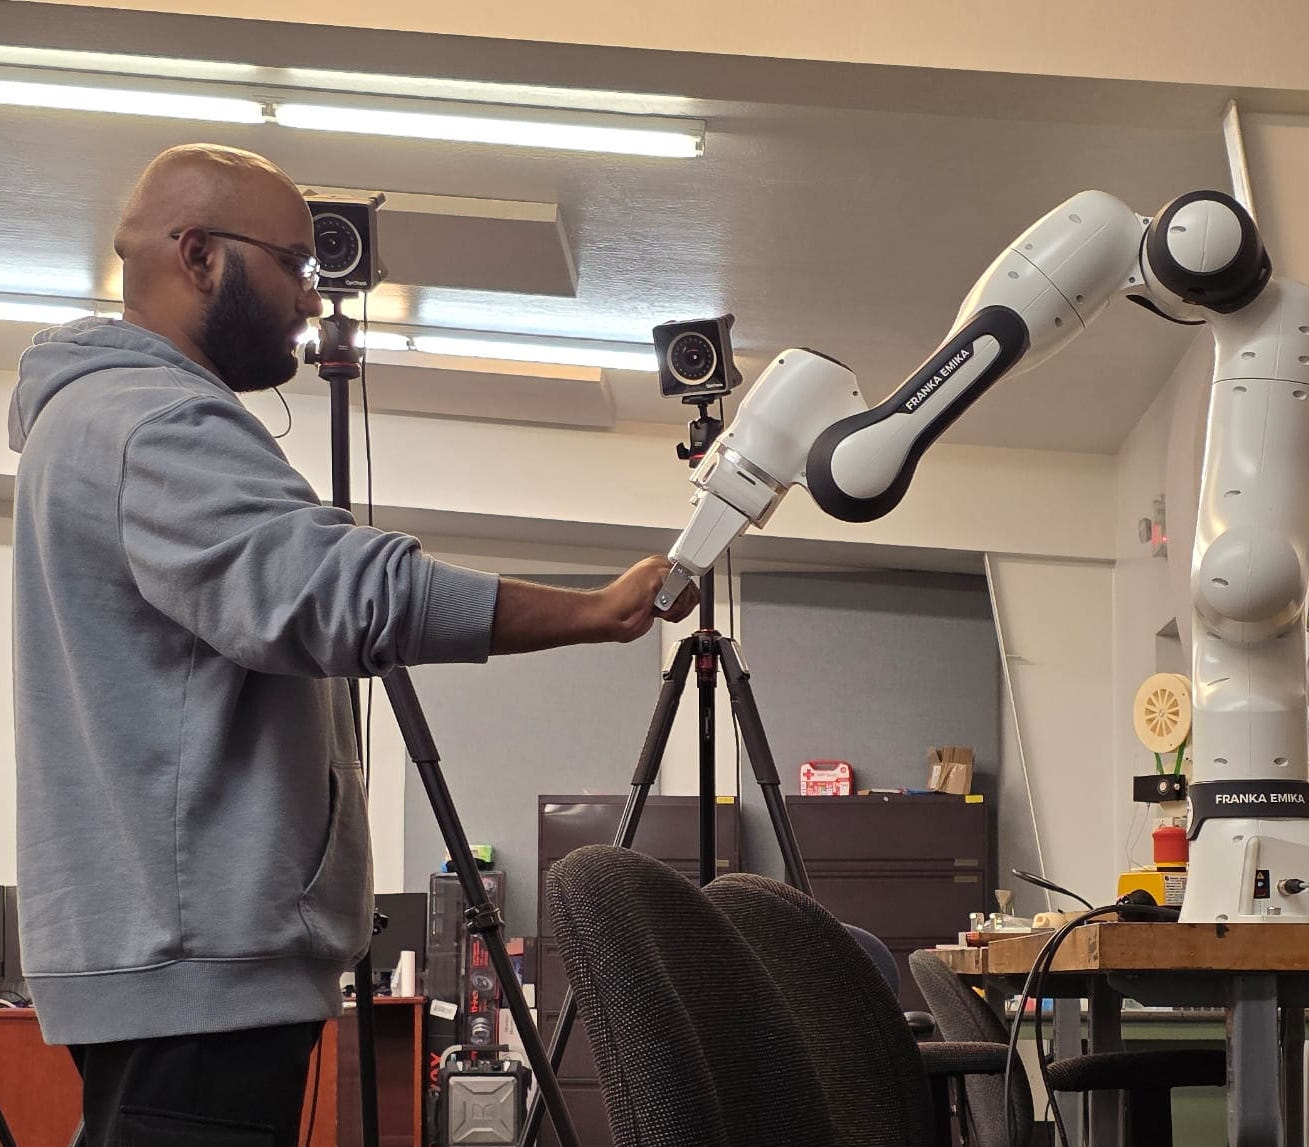
Dual-arm robot learning coordinated therapy behaviors from human demonstrations using Isaac Sim/MuJoCo for imitation learning, MoveIt/ROS2 for control, and motion capture for learning.
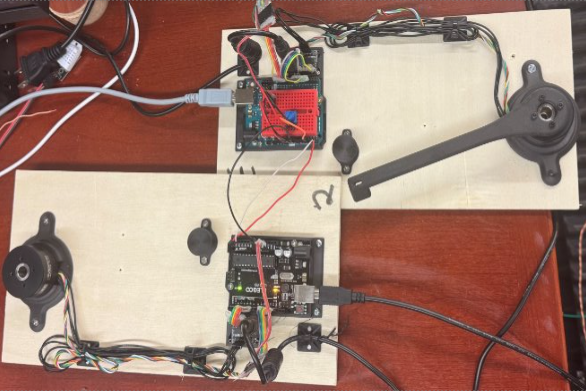
Dynamic Haptic Feedback System
A simple haptic motor system designed to provide dynamic tactile feedback for human-robot interaction (HRI).
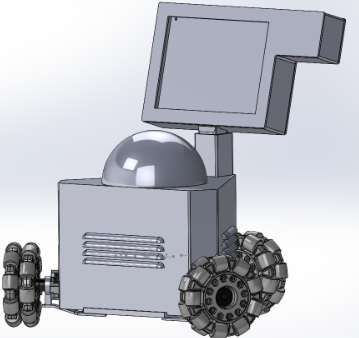
Hamster- Rehabilation Robot
A planar 3-DOF Rehabilitation Robot for upper limb rehabilitation. It is designed to assist patients in performing therapeutic exercises and movements at home.
F1TENTH Autonomous Racing Car
Autonomous navigation stack for an F1TENTH 1/10-scale race car on an NVIDIA Jetson, using ROS 2 Humble, LiDAR-based obstacle detection, and a tuned Nav2 stack for high-speed reactive racing.
Bi-Manual Robotic Therapy
Dual-arm robot learning coordinated therapy behaviors from human demonstrations using Isaac Sim/MuJoCo for imitation learning, MoveIt/ROS2 for control, and motion capture for learning.
Dynamic Haptic Feedback System
A simple haptic motor system designed to provide dynamic tactile feedback for human-robot interaction (HRI).
Hamster- Rehabilation Robot
A planar 3-DOF Rehabilitation Robot for upper limb rehabilitation. It is designed to assist patients in performing therapeutic exercises and movements at home.